Project showcase
Three systems I built in R&D. A leak-test fixture and an analytics platform traced Game Ready pump complaints to their real cause, and C++ software automated robotic validation.
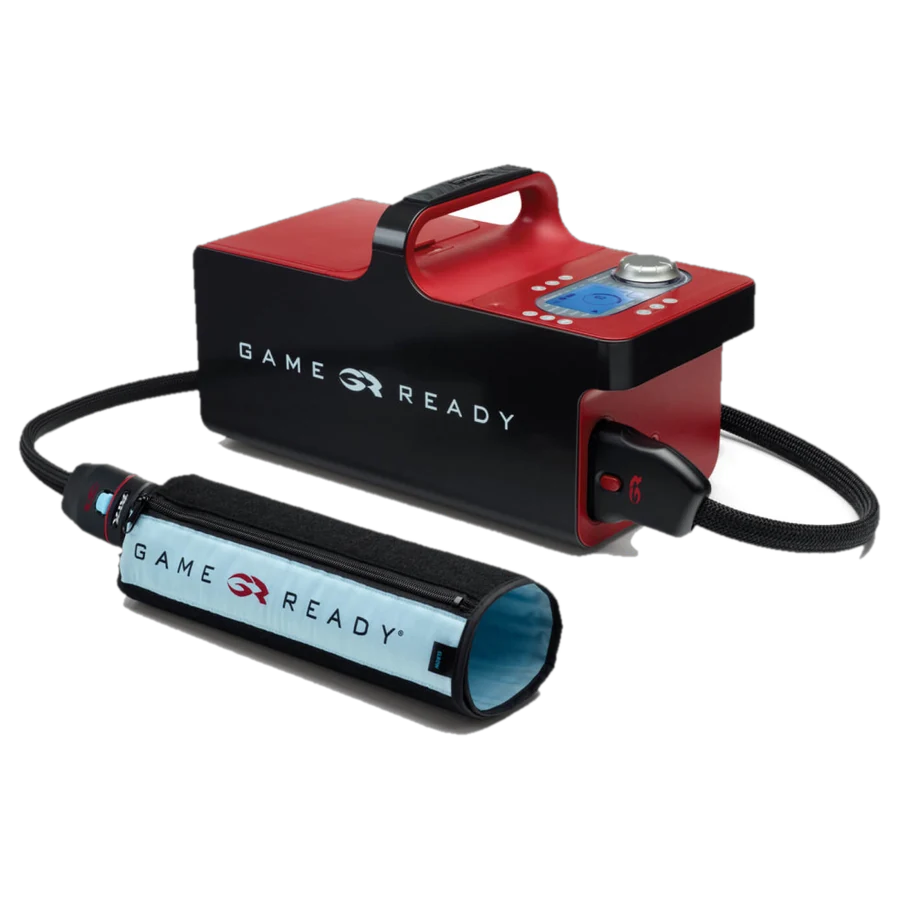
Pump leak-test fixture
What
A LabVIEW and NI myDAQ fixture that holds 10 Game Ready water pumps at 75 psi for 12 hours and flags any that leak.
Why
Game Ready, a cryo-compression therapy system for athletes, drew an alarming number of complaints about leaking water pumps. 115 pumps reported as leaking were pulled from the market, and each needed a controlled test to show whether it really leaked.
How
- Built the water circuit that circulates water to 10 powered pumps at a time, with a fluid pressure sensor on each pump
- Wired the sensors into an NI myDAQ and wrote the LabVIEW program that logs every pump's pressure for 12 hours at 75 psi
- Set a pressure-drop threshold that flags a leak and built the switching that cuts power to that pump automatically
- Tore down every sample pump and checked housings and sealing faces for warping against a granite surface plate with feeler gauges
- LabVIEW
- NI myDAQ
- Pressure sensors
- Data acquisition
- Fixture design
- Mechanical teardown
- Flatness inspection
12-hour run compressed to seconds. Illustrative traces, not Avanos data.
Results
- Pressure-tested the 115 returned pumps, 10 at a time
- Only a handful lost pressure, and teardown found no warping
- Showed the hardware could not explain the complaint rate, which pointed the investigation at the failure reports
Failure reporting analytics
What
A full-stack internal platform that pulls customer complaints from Salesforce and service-center findings from SAP and analyzes them side by side.
Why
The fixture showed most pumps held pressure, so the problem had to be in how failures were reported. Complaints land in Salesforce, operators log root causes in SAP, and R&D engineers were not trained on SAP, which holds far more data than they need.
How
- Pulled SAP and Salesforce records through REST APIs
- Analyzed failure reports in Python with pandas, SciPy and Matplotlib, behind a Streamlit front end deployed through CI/CD
- Found the discrepancy. Operators who traced a leak to a non-pump fault still replaced pumps that looked old or rusted, logging them as pump failures and skewing the data
- Wrote and ran the full CAPA: updated service work instructions, retrained operators, added SAP failure codes and kept the SAP and Salesforce reconciliation running
- Python
- REST APIs
- pandas
- SciPy
- Matplotlib
- Streamlit
- SAP
- Salesforce
- CI/CD
- CAPA
Where the data comes from
What I built
SAP
Example record the analysis flags
- Salesforce complaint
- Pump leaking
- SAP root cause
- Non-pump fault
- SAP action
- Pump replaced, looked old or rusted
- Flag
- Mislogged pump failure
Simplified system diagram. Example record is illustrative.
Results
- CAPA covering $40M of inventory
- Avoided switching contract manufacturers
- 95% faster failure analysis
- R&D and Quality engineers get failure data without SAP training
6-axis robot validation software
What
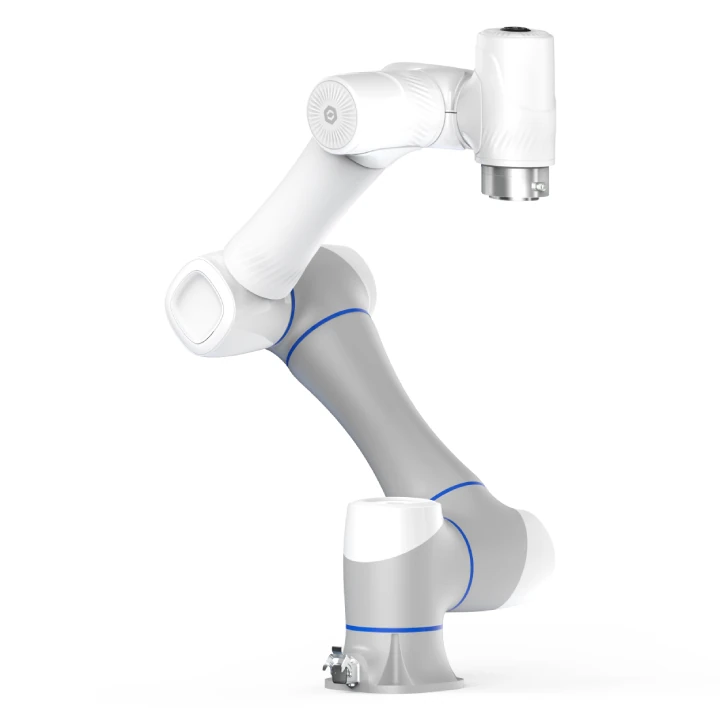
C++ control software that turns a feeding-tube placement path into motion for a DOBOT CR5A 6-axis robot, used to validate the Avanos CORTRAK 2 enteral access system.
Why
Validation of the product ran by hand, costing more than 1000 hours.
How
- Parsed 3D CSV points of a tube placement path and interpolated them into a smooth trajectory
- Computed the joint translations and rotations to follow the path and converted them into robot commands
- Streamed the commands to the robot over TCP
- Built a MATLAB GUI to control the robot and began software validation to ISO 12207
- C++
- Path interpolation
- Inverse kinematics
- TCP/IP
- MATLAB
- DOBOT CR5A
- ISO 12207
Results
- 1000+ hours of manual validation automated
Additional projects
Enteral feeding tube test fixture
Designed, built and validated a feasibility test fixture in two weeks, a deadline my supervisors did not expect me to hit. It tested whether an enteral feeding tube withstands flow rates above its intended use, following ISO requirements for enteral feeding tube testing.
- Fixture design
- Flow testing
- ISO test methods